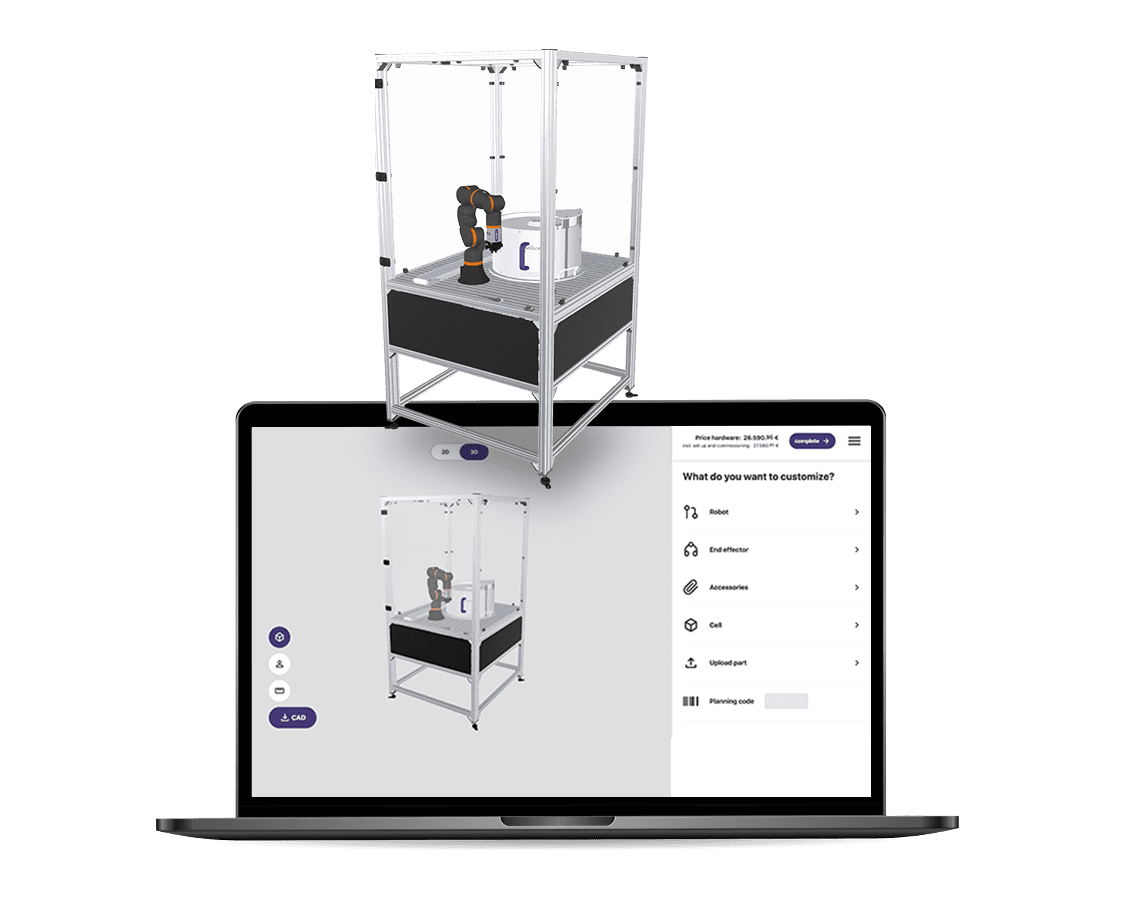
Schmalz CobotPump | Bomba de vacío eléctrica para cobots | grande
Variantes: Fairino FR3-30
Los modelos CobotPump están diseñados para el manejo eficiente de materiales en sistemas robóticos. Su robusta tecnología de vacío eléctrica ofrece fiabilidad, flexibilidad y un diseño compacto. Gracias a su potente rendimiento, la CobotPump garantiza un control preciso y tiempos de respuesta rápidos, ideal para tareas de automatización exigentes.
La integración en sistemas de automatización existentes es sencilla gracias a interfaces digitales consolidadas como el conector M12 de 8 polos. Una interfaz NFC permite configurar los parámetros y transferir datos cómodamente desde el móvil. El software intuitivo y la funcionalidad plug-and-play reducen el tiempo de instalación y garantizan una puesta en marcha rápida.
Perfecta para el manejo preciso de materiales, la logística y las aplicaciones de producción: la CobotPump ofrece eficiencia, versatilidad y facilidad de uso.
Nuestros destacados
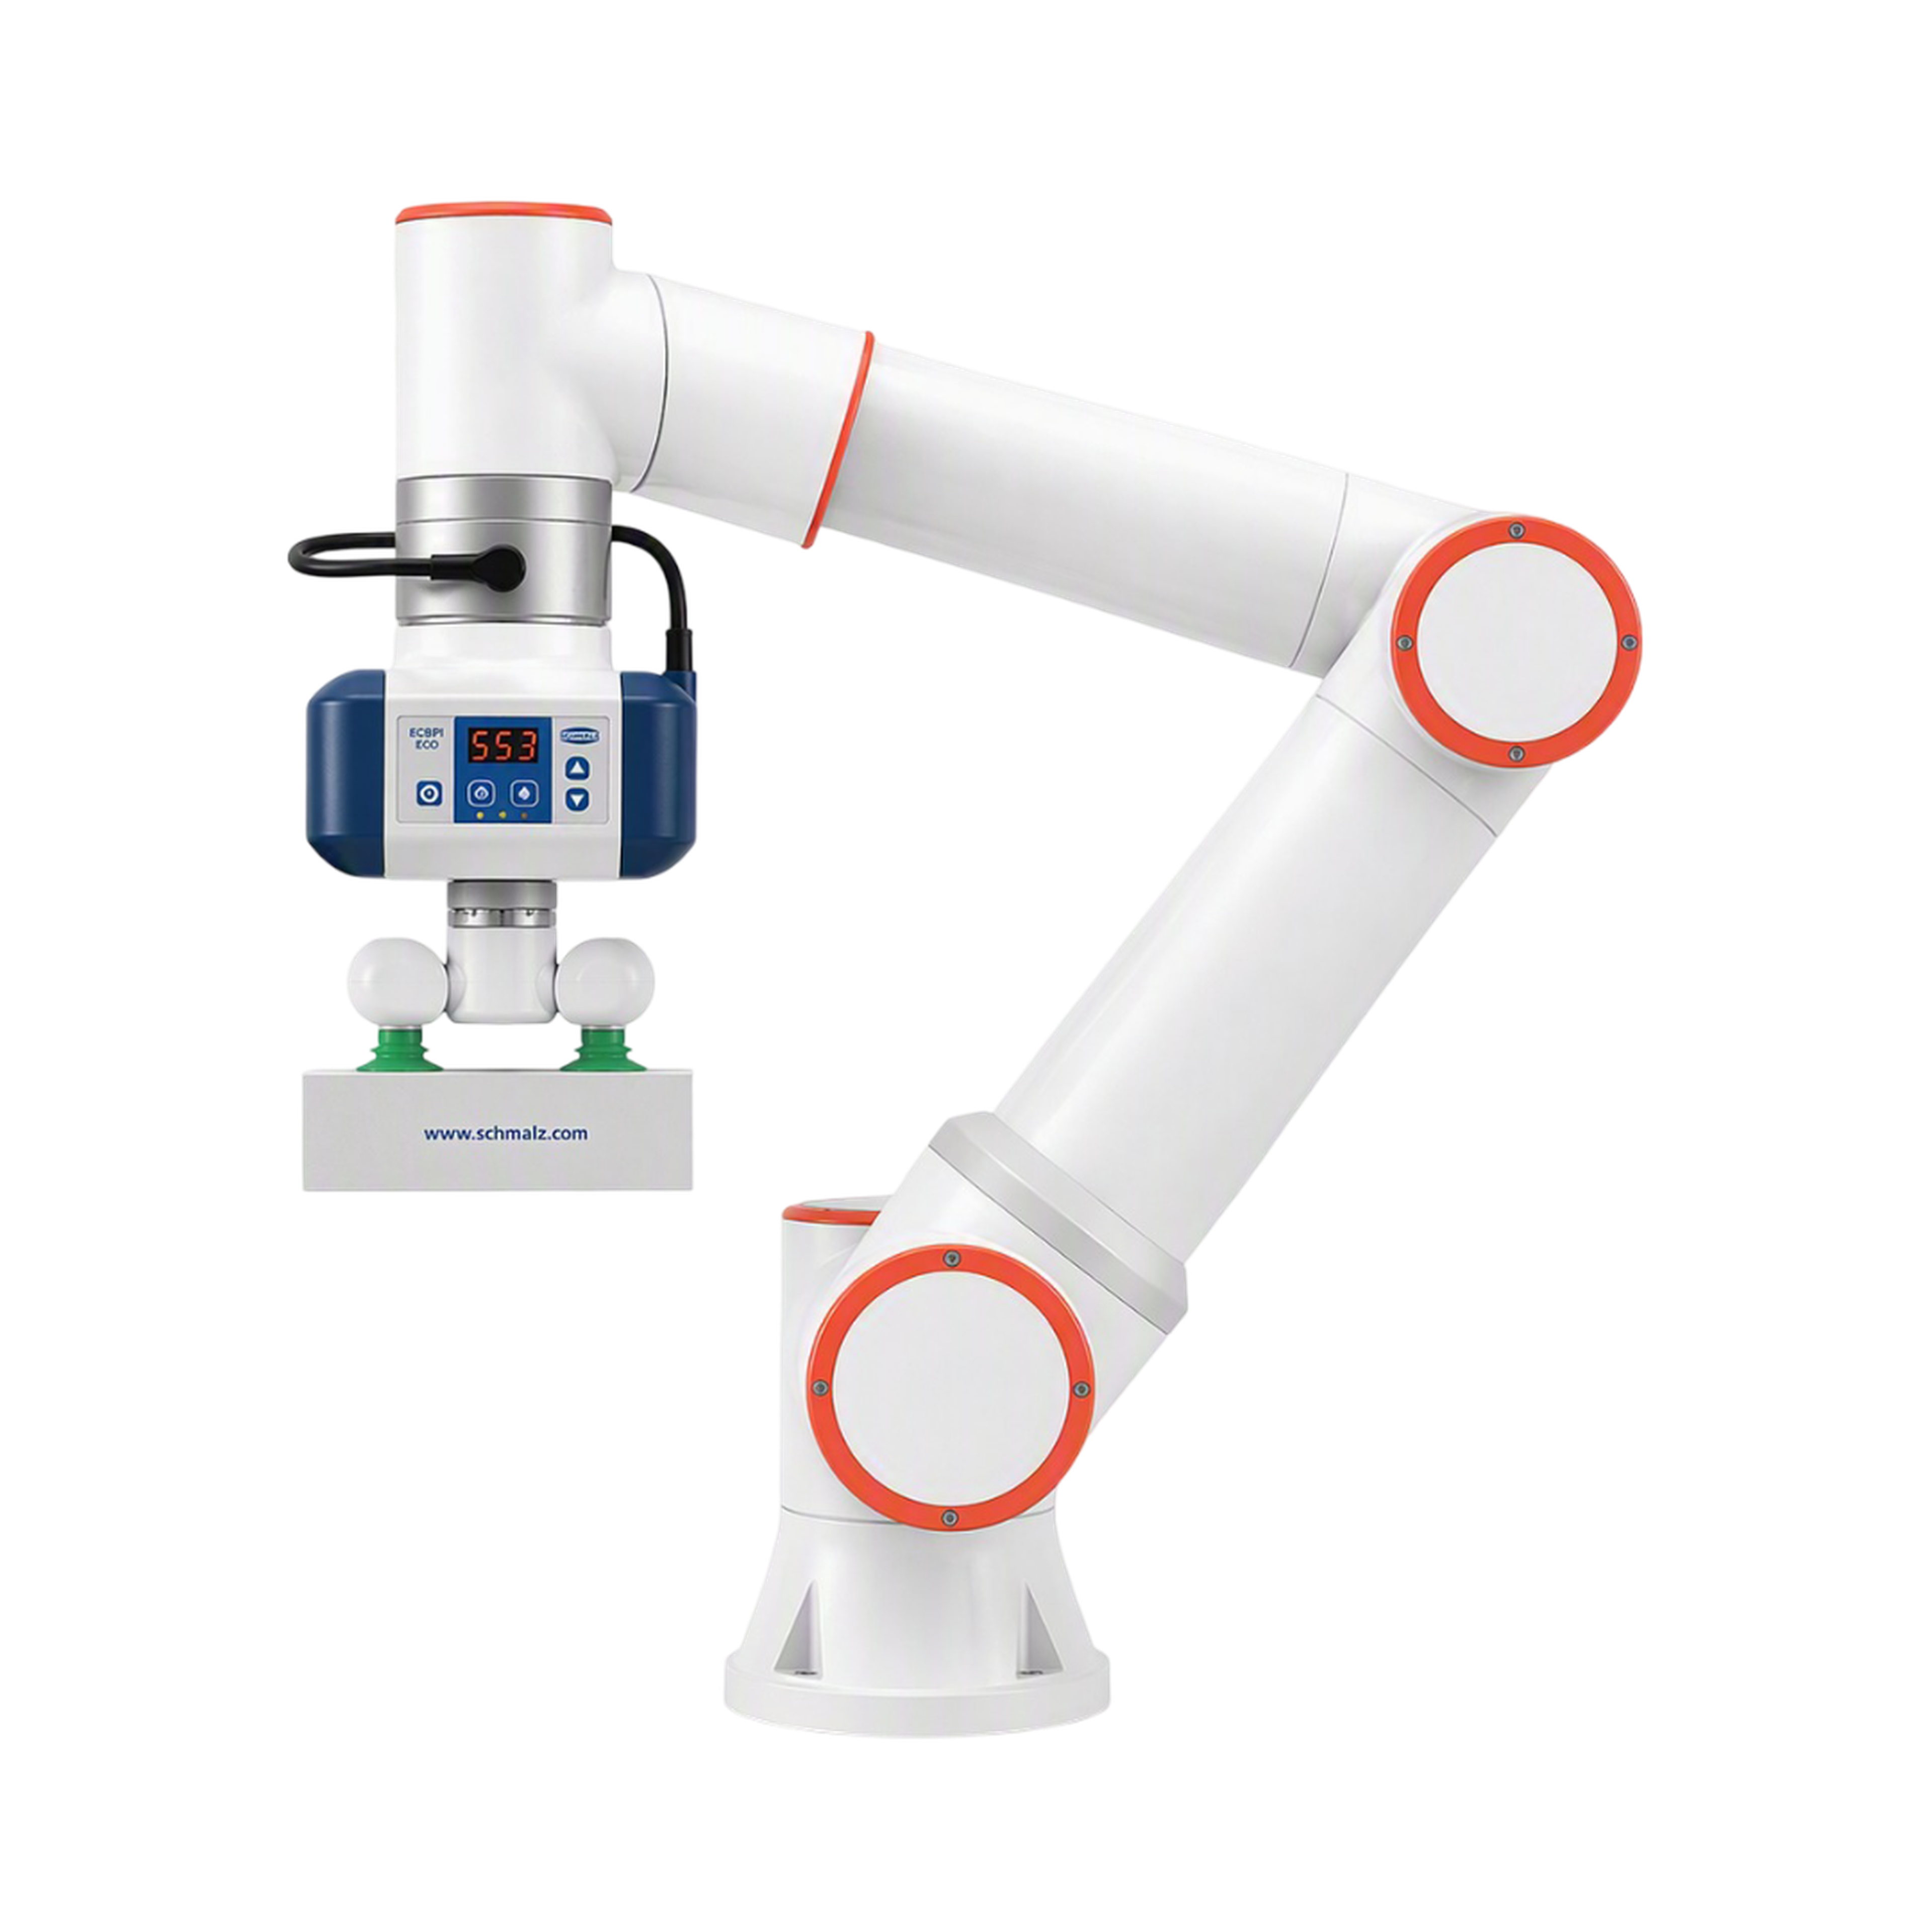
A comprehensive solution for rapid FAIRINO integration
With the ECBPi FAIRINO from Schmalz, users receive a fully coordinated robotics kit for connecting and integrating the CobotPump ECBPi with FAIRINO lightweight robots. The kit significantly simplifies the implementation of automation projects, as all the components required for mechanical and functional integration are optimally coordinated. This significantly reduces the effort involved in planning, procurement and installation. The compact design is suitable for use with FAIRINO robots from the FR3, FR5 and FR10 series and provides the ideal basis for efficient handling, pick-and-place and logistics processes. This enables companies to move more quickly from the initial project idea to a productive robotic application.
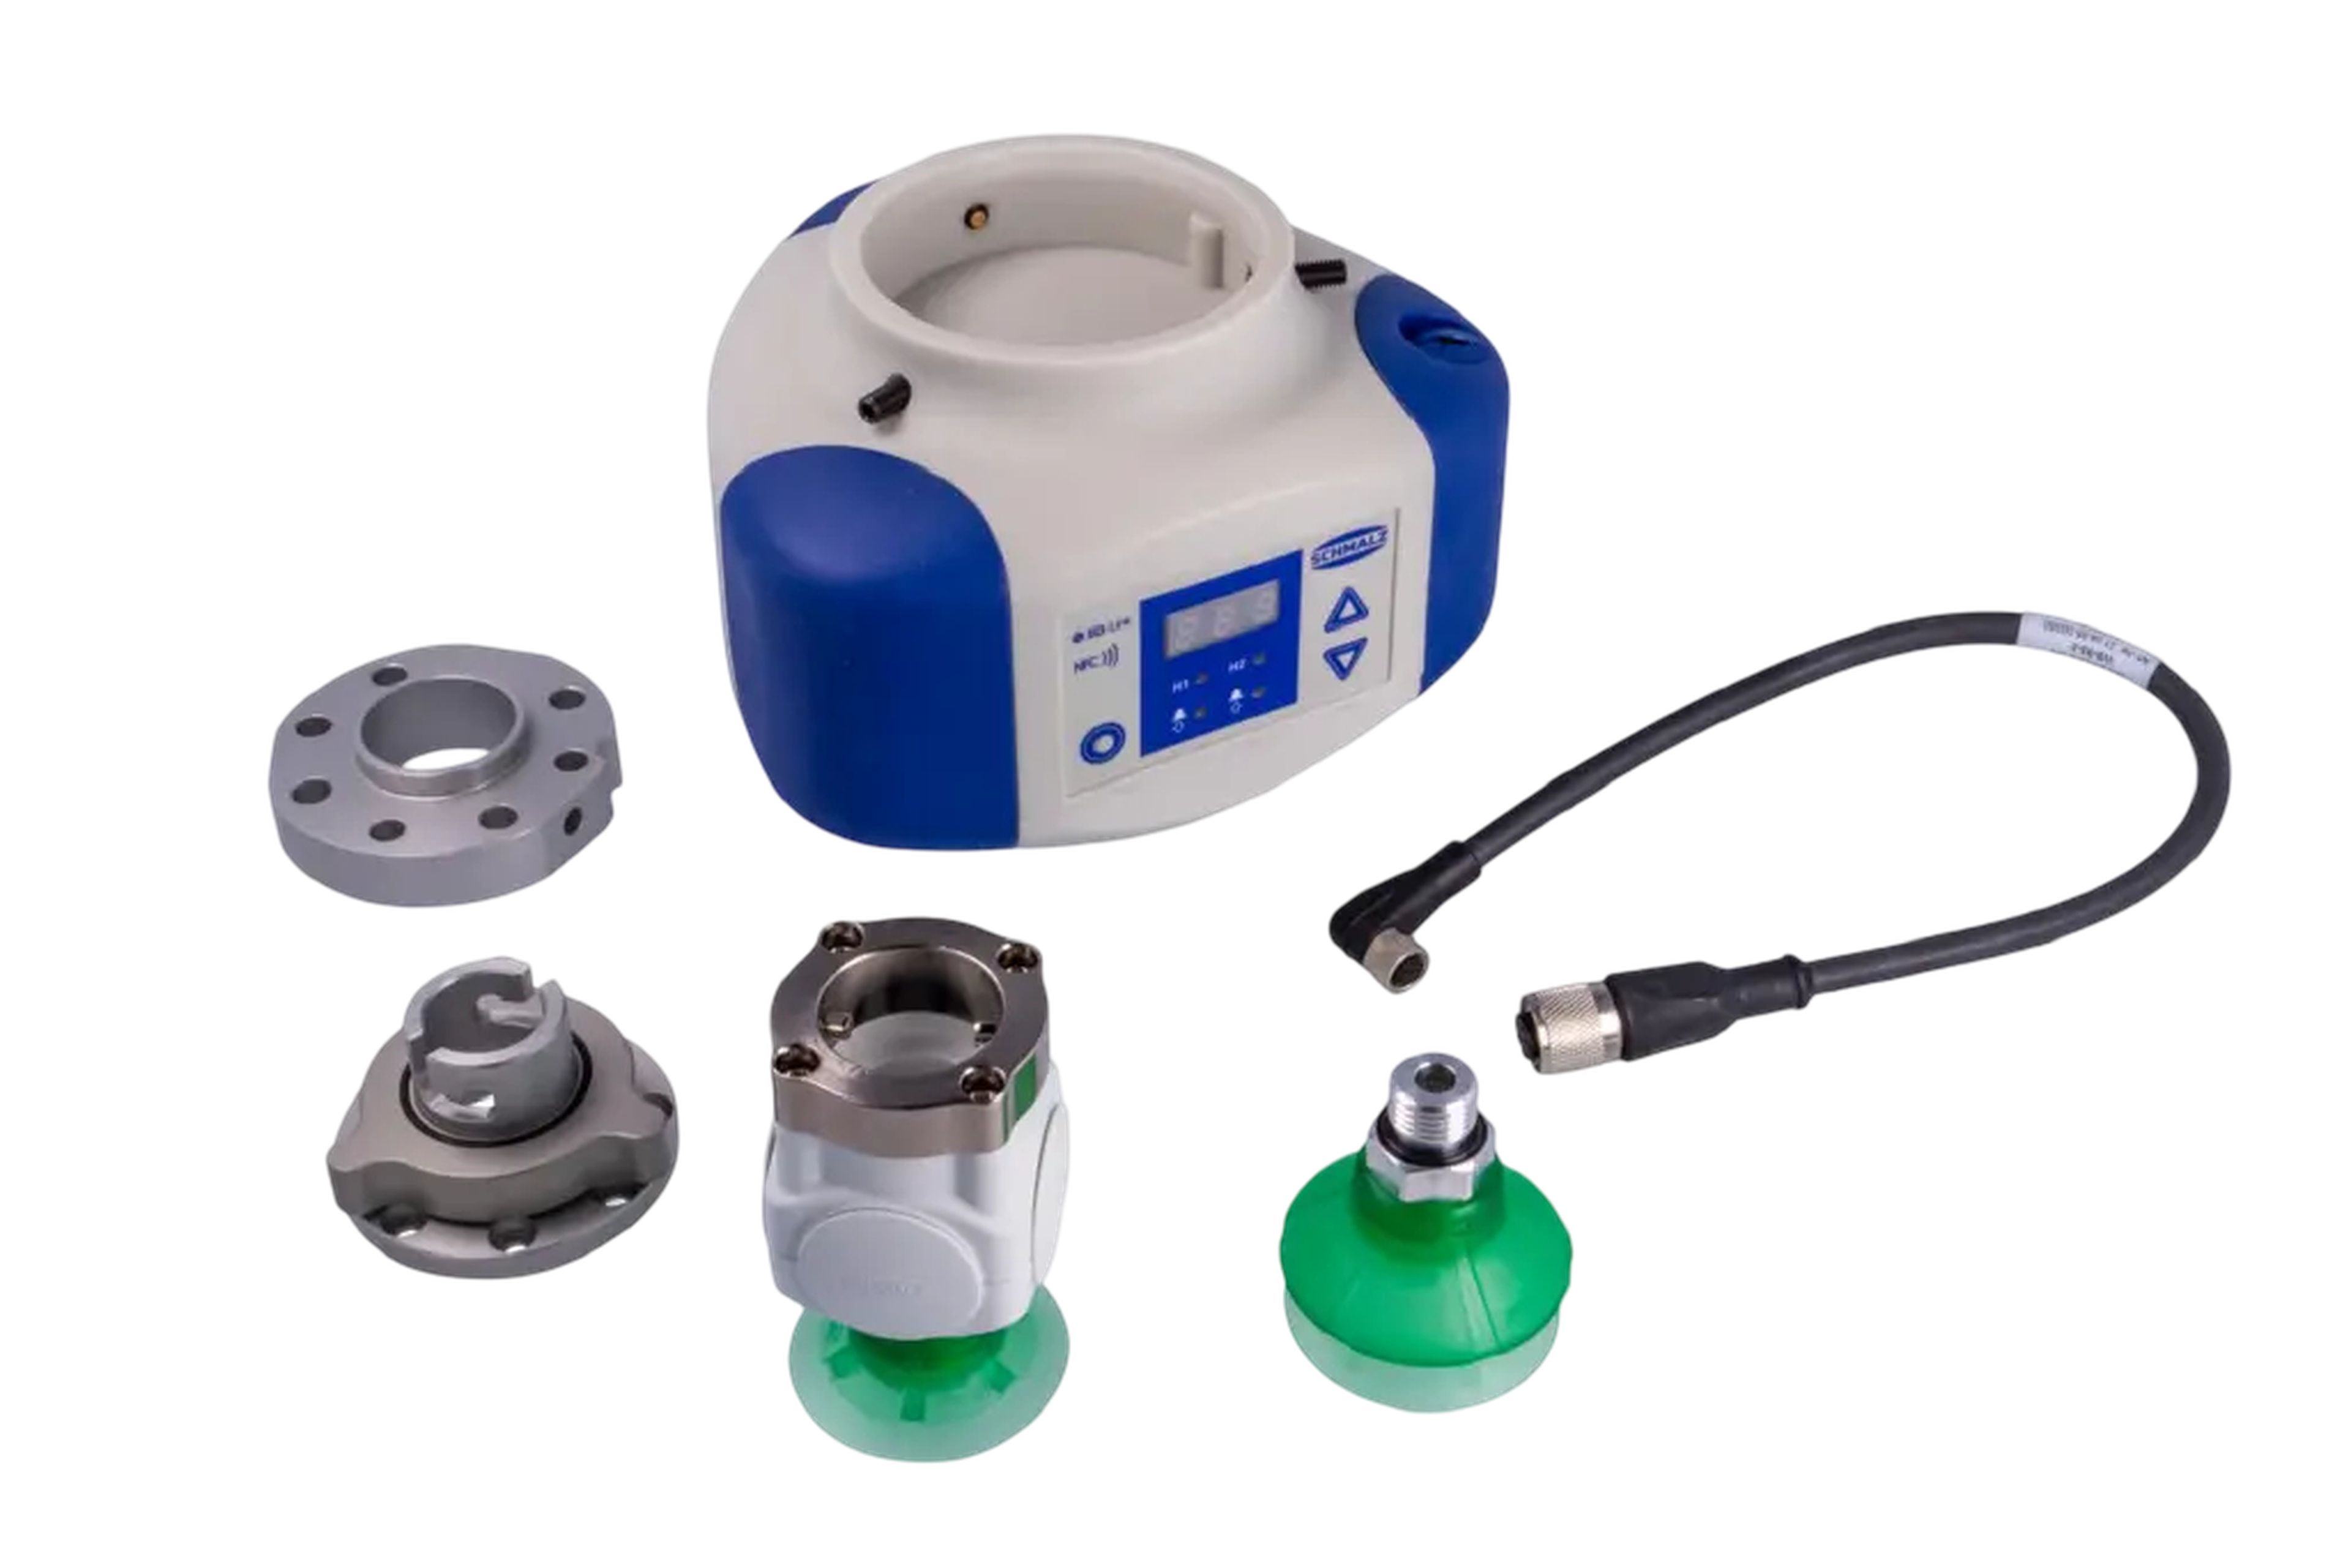
Flexible vacuum automation for dynamic processes
The ECBPi FAIRINO combines the electric vacuum technology of the CobotPump ECBPi with a modular end-of-arm concept for maximum application flexibility. Different workpieces and varying requirements can be handled efficiently using compatible vacuum end-effectors and accessory solutions, without the need to redesign the entire gripper structure. The vacuum generation system, integrated directly onto the robot, reduces the need for external infrastructure and supports a lean cell design. At the same time, the compact arrangement of the components ensures low loads on the robot joint and enables dynamic movement sequences. This makes the system the ideal choice for companies seeking to implement flexible automation solutions with high process reliability and rapid adaptability.
Sistemas económicos creados con RBTX
Concierte una videollamada gratuita con nuestros expertos