Operator HMI | Interfaz de software para igus Robot Control
Variantes: Software
Interfaz de usuario intuitiva para su sistema robótico
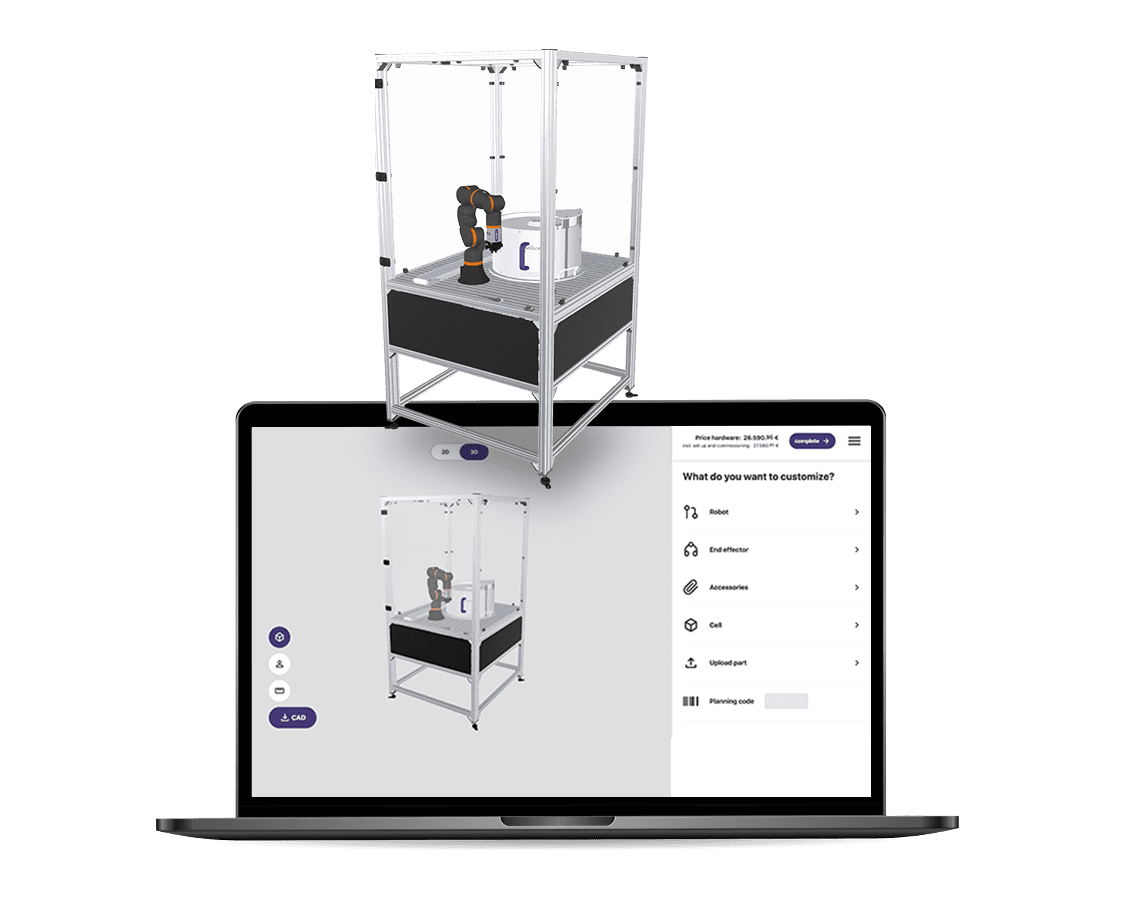
Con el iRC Operator HMI, puede manejar su sistema robótico de forma sencilla, segura y eficiente, sin necesidad de conocimientos de programación. La interfaz de usuario basada en web cubre el hueco entre las soluciones sencillas con pulsadores y el software iRC completo.
Como servicio web, la aplicación se ejecuta directamente en el sistema de control y puede utilizarse de forma flexible a través de un HMI, un PC, una tablet o un smartphone. El inteligente concepto de dos niveles permite una clara separación entre operación y configuración.
Funciones como el inicio de programa, la selección de programa, el ajuste de velocidad, la supervisión del estado, el análisis de errores y completas estadísticas ayudan a reducir los errores de manejo, aumentar la productividad y garantizar un control eficiente de la instalación.
Nuestros destacados

Intuitive operation for maximum productivity
With the iRC Operator HMI, users can operate robotic systems quickly, safely and without in-depth programming knowledge. The intuitive user interface provides exactly the functions required for day-to-day operation and reduces complexity to the essentials. As a browser-based application, the HMI runs directly on the controller and can be used flexibly via the HMI, a PC, a tablet or a smartphone. The intuitive programme selection, rapid system authorisation and clear display of the robot status ensure more efficient processes and higher productivity in manufacturing.

Greater security through clearly defined roles and full transparency
The iRC Operator HMI creates a clear separation between operation and programming. Whilst operators can carry out production tasks safely and easily, technicians retain full control over set-up and adjustments within the iRC software. Protection against unintended programme changes reduces operator errors and enhances process reliability. In addition, detailed statistics, dynamic fault analysis and flexible speed settings enable continuous optimisation of the robotic system. This minimises downtime and sustainably increases system availability.
Sistemas económicos creados con RBTX
Concierte una videollamada gratuita con nuestros expertos