Dobot Rover X1 Explorer Industrial | Perro robótico

Dobot Rover X1 Explorer
El Dobot Rover X1 Explorer es un robot cuadrúpedo de inspección y desarrollo impulsado por IA, diseñado para entornos difíciles. Su sistema de propulsión híbrido de ruedas y patas le permite alcanzar velocidades de hasta 3 m/s, superar obstáculos de hasta 16 cm de altura y afrontar pendientes de hasta 35°.
Las cámaras delanteras y traseras, equipadas con sensores de profundidad RGB-D, proporcionan datos ambientales precisos para la evitación autónoma de obstáculos, el seguimiento visual de personas y la interacción por voz. Con una autonomía de hasta 3 horas, una capacidad de carga útil de entre 3 y 7 kg, un SDK integrado y compatibilidad con complementos como LiDAR o cámaras infrarrojas, el Rover X1 es ideal para aplicaciones de inspección, recopilación de datos, investigación y robótica autónoma.
Nuestros destacados
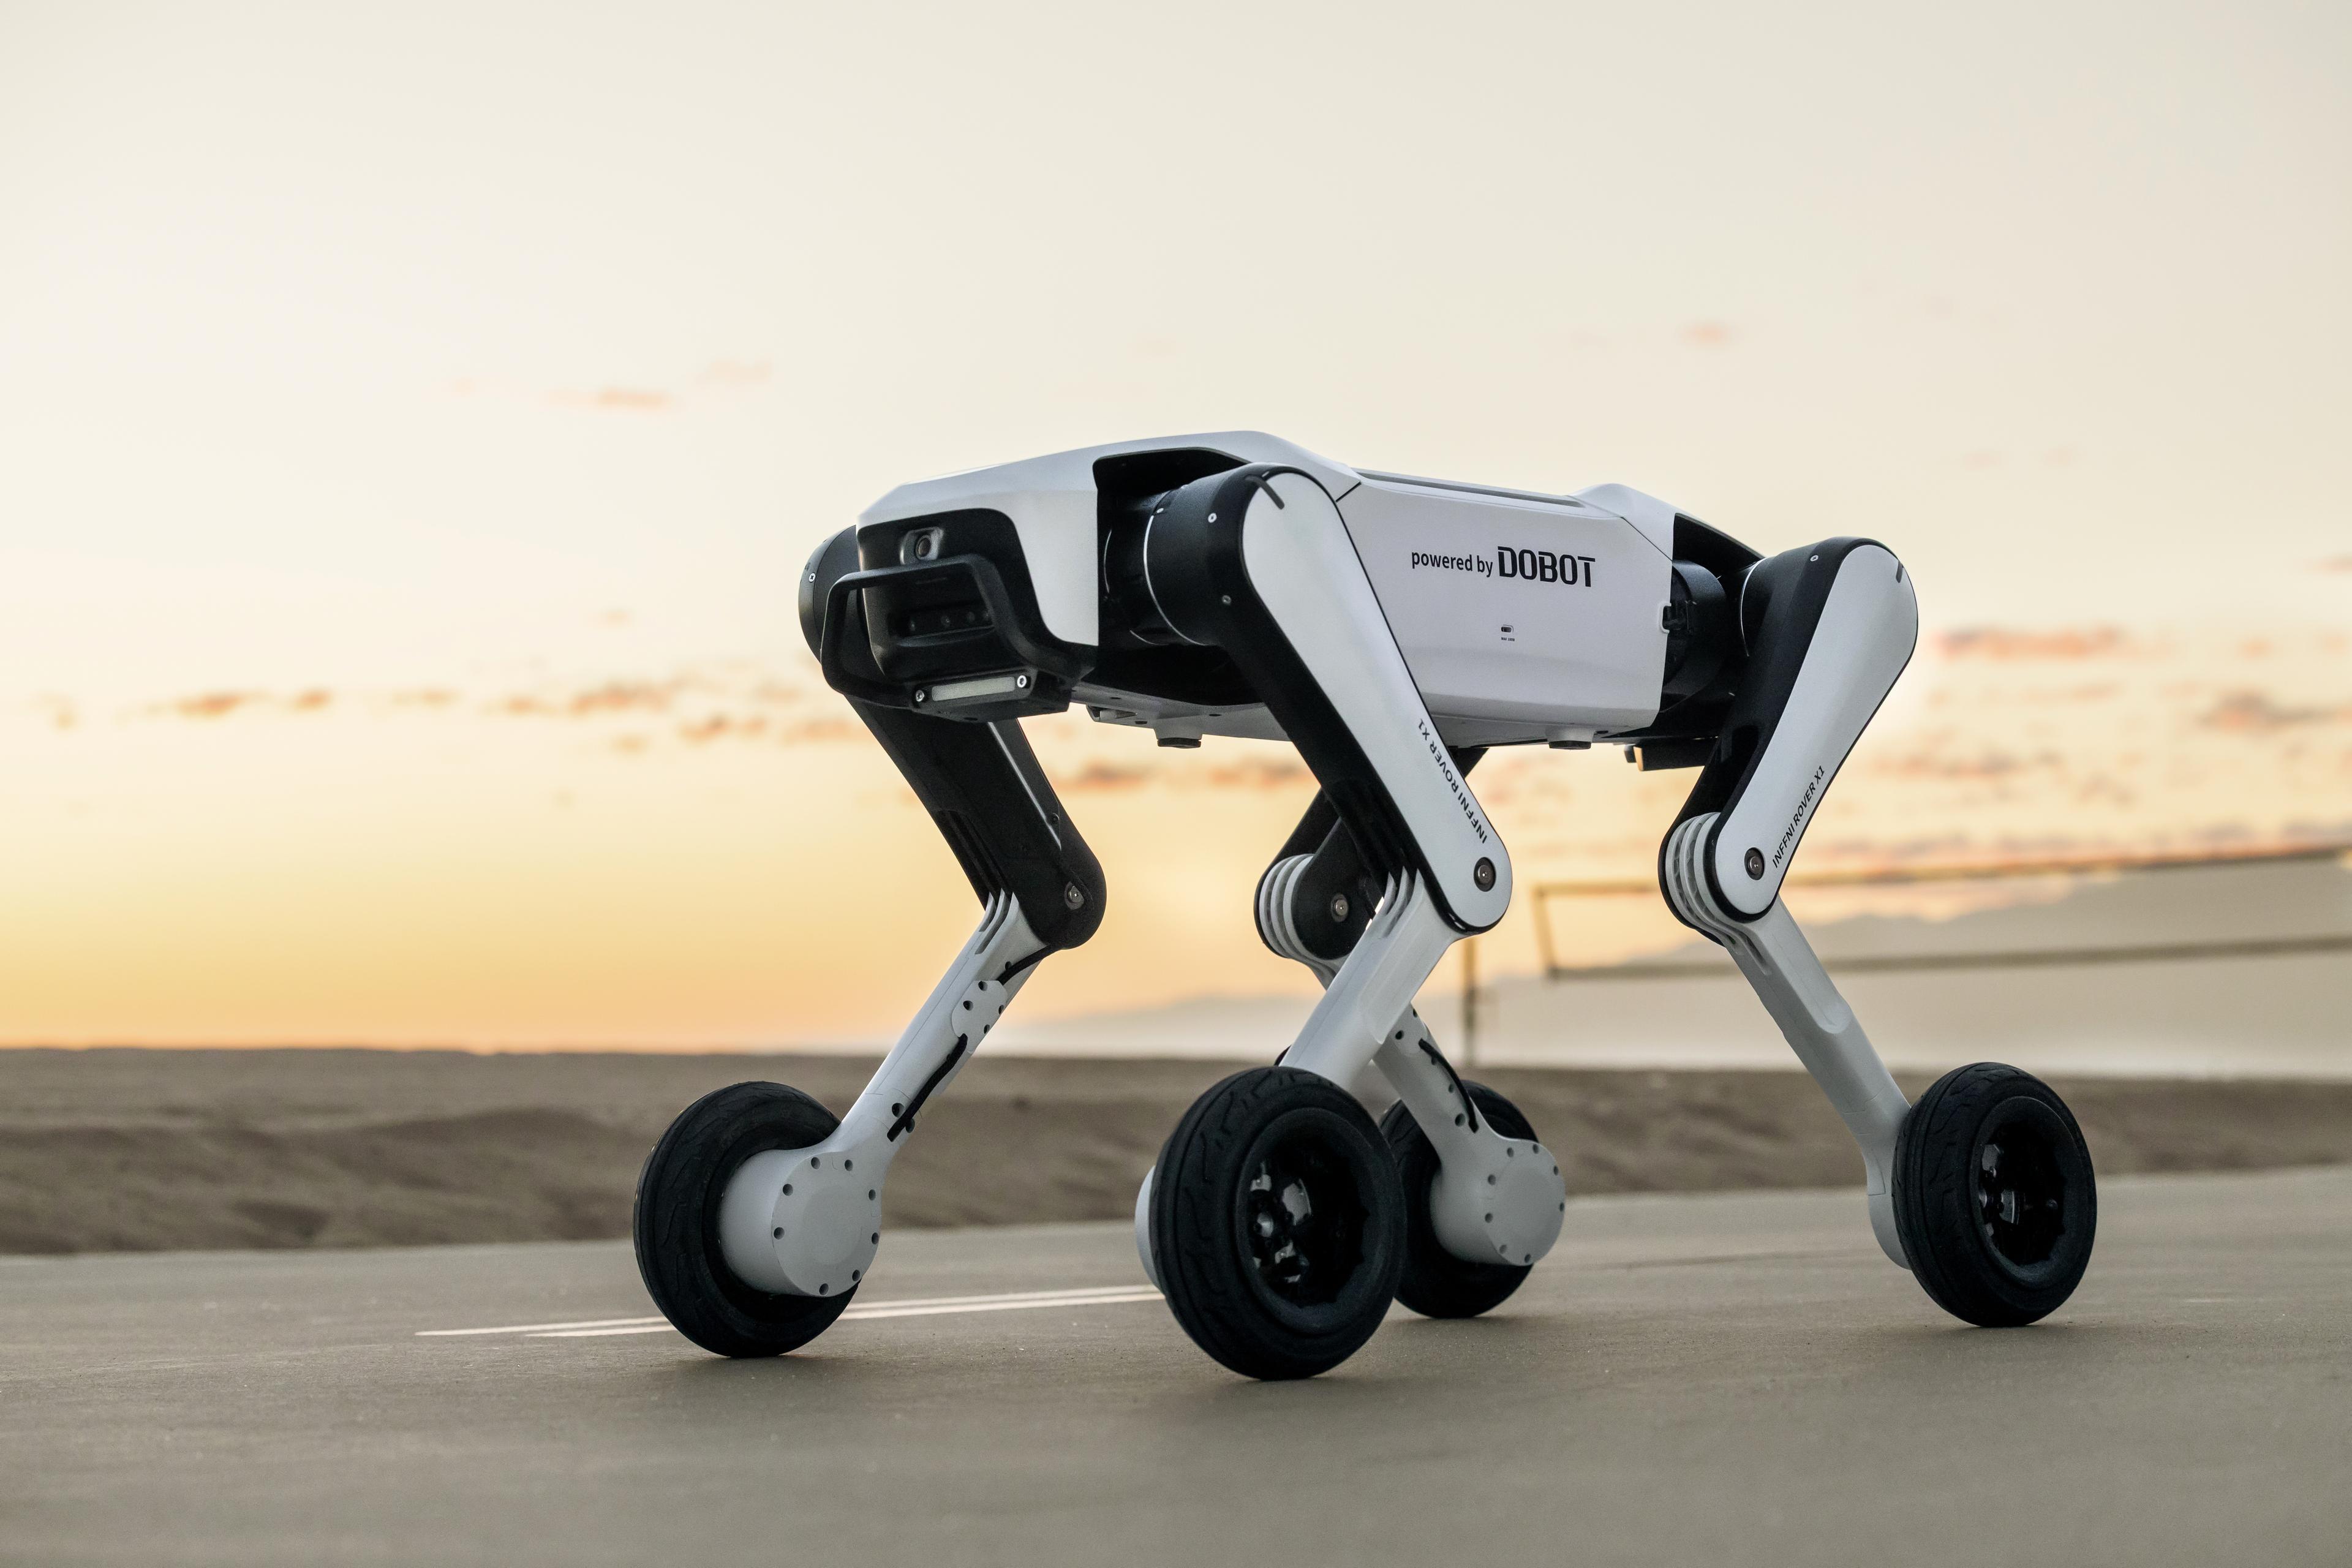
Differences between the Rover X1 Explorer and the Rover X1
The Rover X1 Explorer is the development- and application-oriented variant of the Rover X1, whilst the standard X1 is primarily positioned as a consumer robot for everyday use, follow mode, transporting small loads, content creation and home patrolling, the Explorer broadens the focus to include research, education, inspection and secondary development. It features front and rear RGB cameras with depth sensing, integrated AI functions such as obstacle avoidance, visual following and voice interaction, as well as a unified SDK for high-level tasks and low-level real-time control. It is equipped with an 8,000 mAh battery, offering up to 3 hours’ runtime, a payload of 3 to 7 kg, and optional extras such as LiDAR or infrared cameras.
Programming, Control Systems & Technical Features of the Dobot Rover X1 Explorer
The Rover X1 Explorer is designed as an open robotics platform for developers, research teams and educational institutions. The unified SDK allows high-level functions such as navigation, task logic and motion sequences to be combined with low-level access to real-time control, speed, status and motion behaviour. It supports C++ and Python SDKs, camera SDKs and simulation environments such as Isaac Gym. The robot is controlled via an app using Wi-Fi, a Bluetooth controller and, in future, 4G remote control via an OTA upgrade. Technically, it features 1080p front and rear cameras, depth sensors, AI-assisted route planning, obstacle avoidance, follow mode, voice interaction, speeds of up to 3 m/s and a climbing ability of 30 to 35°.
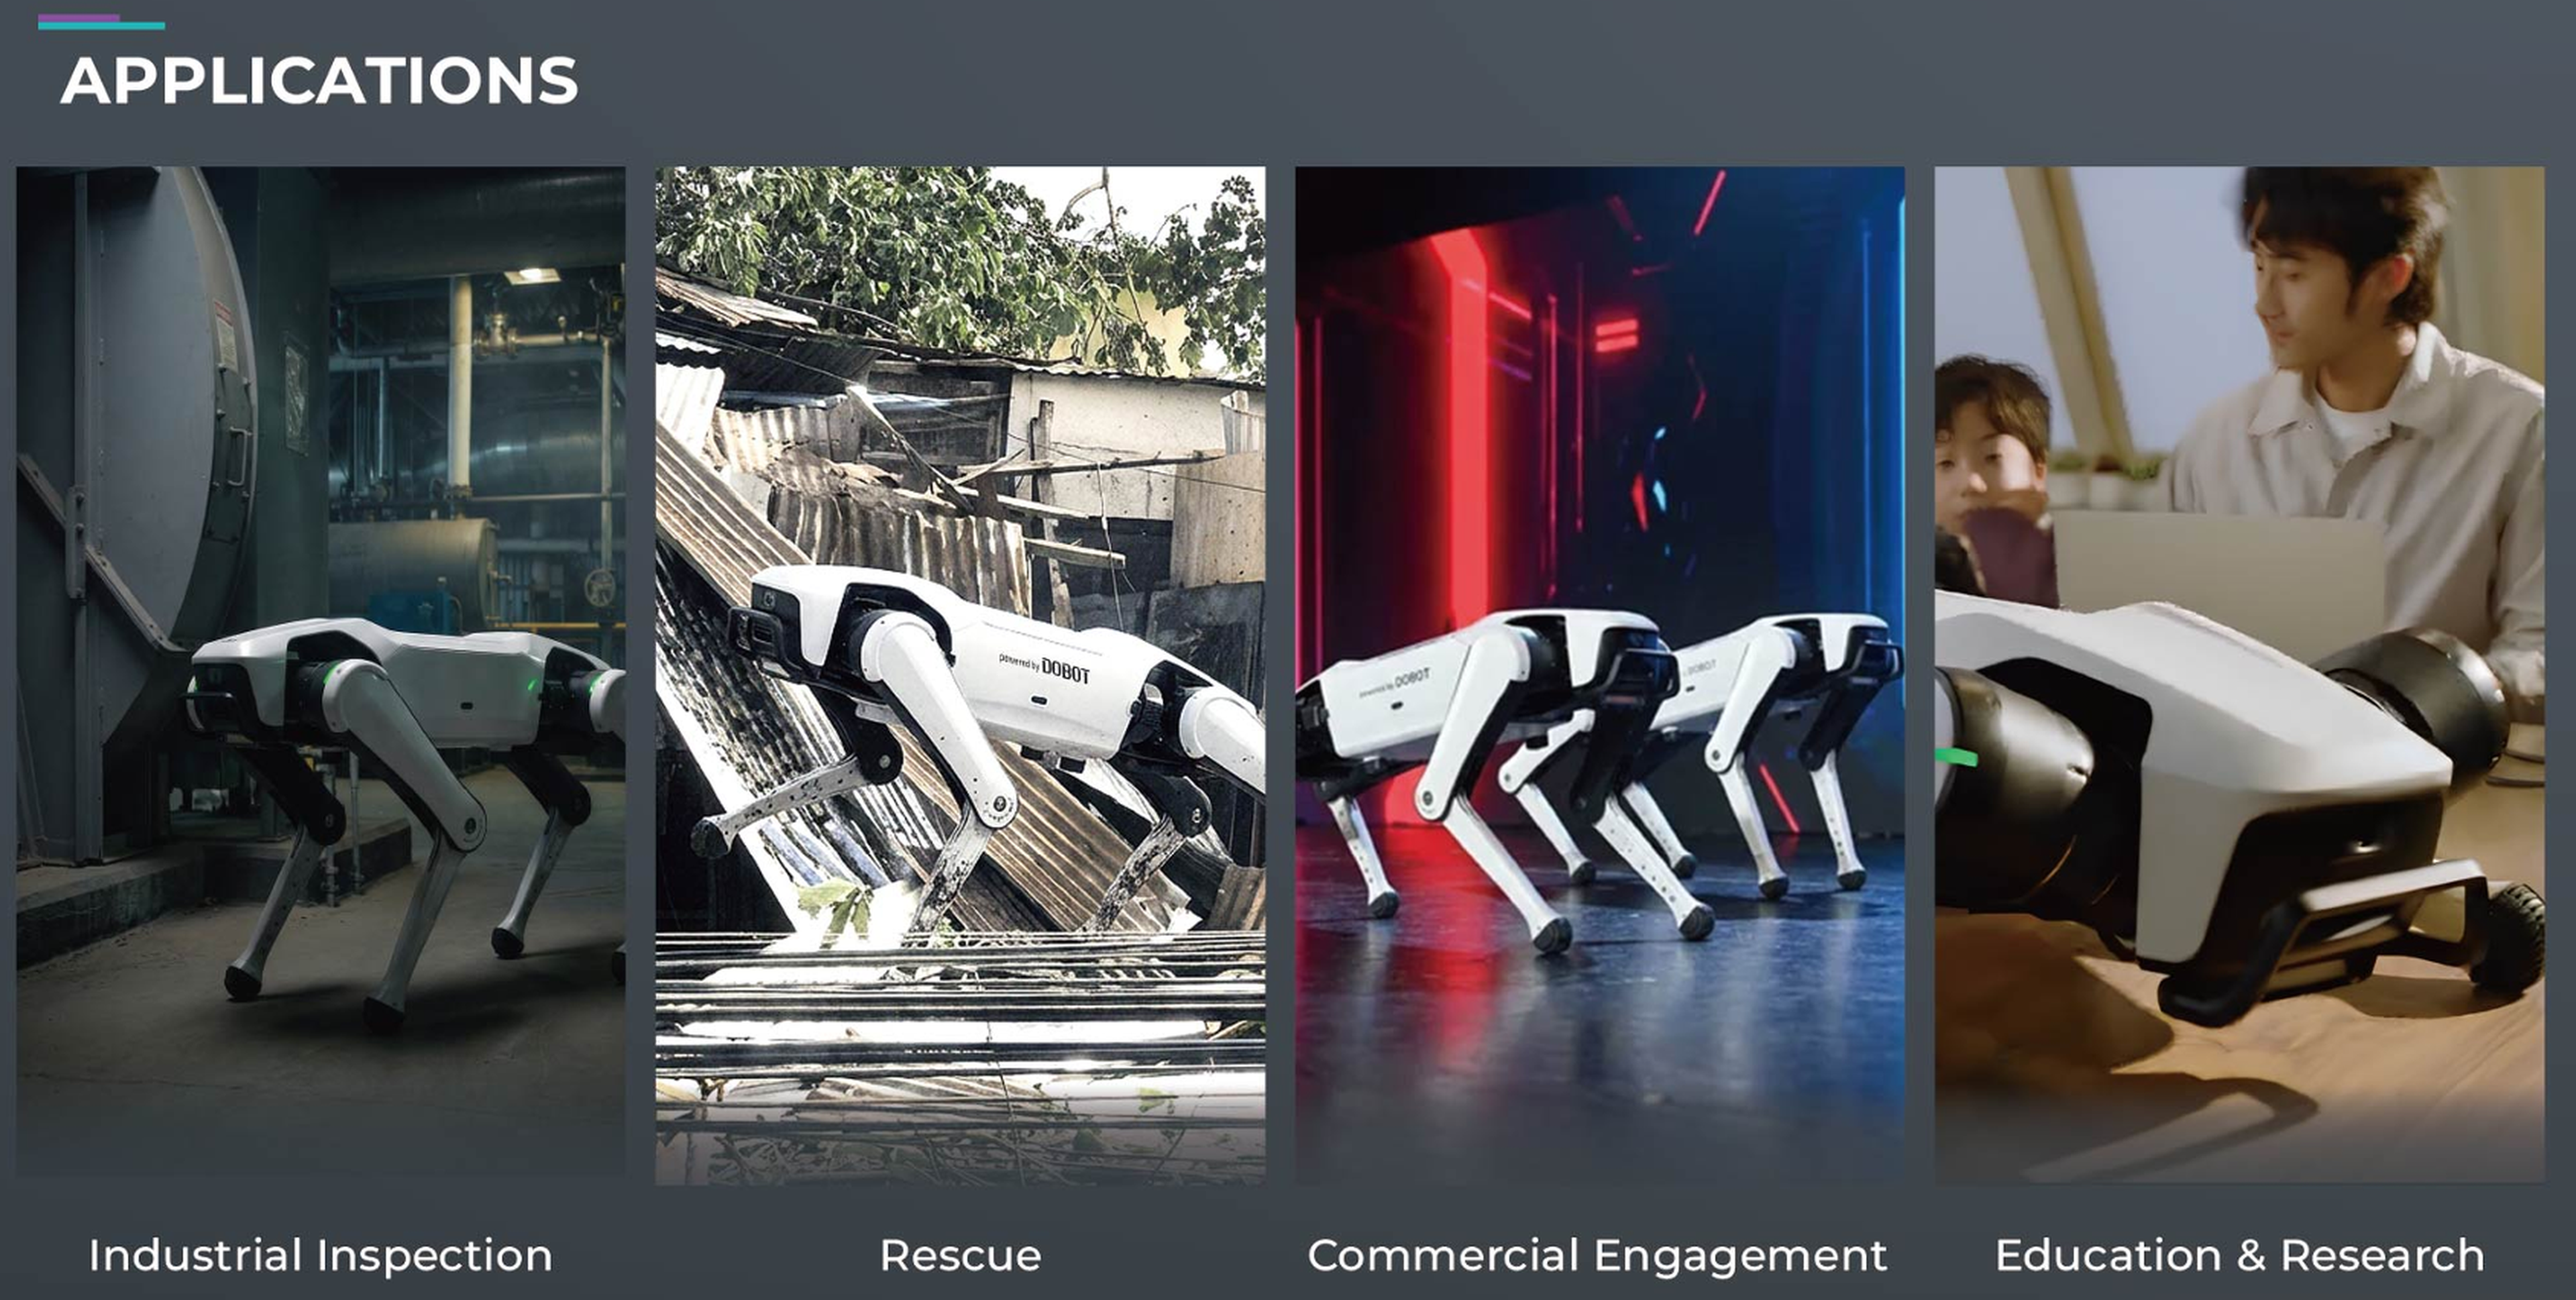
Possible applications & target groups for the Dobot Rover X1 Explorer
The Rover X1 Explorer is ideal for anyone who wishes not only to demonstrate mobile robotics, but also to put it into practical use, test it or further develop it. In industry, it can carry out inspection rounds, data collection and environmental monitoring in areas that are difficult to access or pose a high risk. In education and research, it serves as a practical platform for AI, SLAM, motion control, sensor fusion and autonomous navigation. It is also relevant for rescue scenarios, campus patrols, guided tours, prototyping, robotics laboratories and content creation. The Rover X1 Explorer is designed for universities, research institutes, system integrators, development teams, industrial users and companies seeking a compact, expandable quadruped platform.
Sistemas económicos creados con RBTX
Concierte una videollamada gratuita con nuestros expertos


